MIT 2.156 · 2024Sketch-to-CAD: CAD Models from Hand-Drawn Sketches
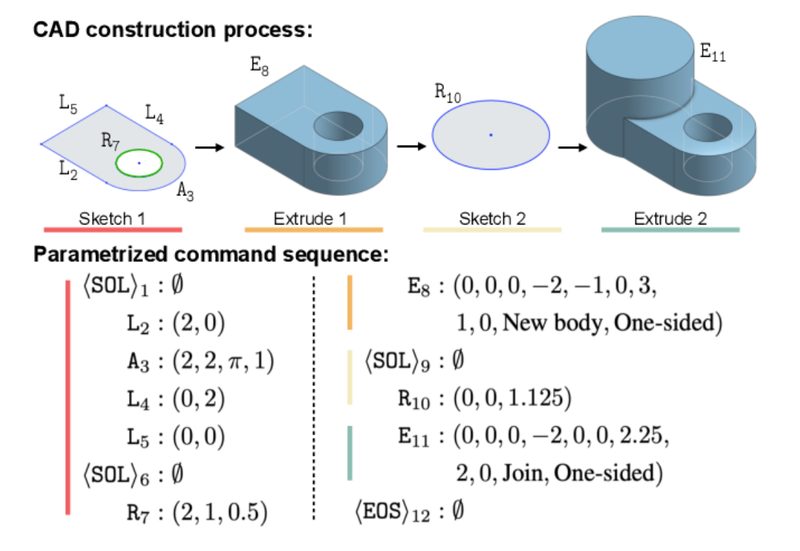
Built a dataset of 166K hand-drawn sketches paired with DeepCAD models, and a CNN encoder with a Transformer decoder that predicts parametric CAD sequences (91% command accuracy).
Robotics, machine learning, and engineering projects, plus things built for fun.
Robotics, machine learning, and engineering projects from MIT, Stanford, and École Polytechnique.
MIT 2.156 · 2024Built a dataset of 166K hand-drawn sketches paired with DeepCAD models, and a CNN encoder with a Transformer decoder that predicts parametric CAD sequences (91% command accuracy).
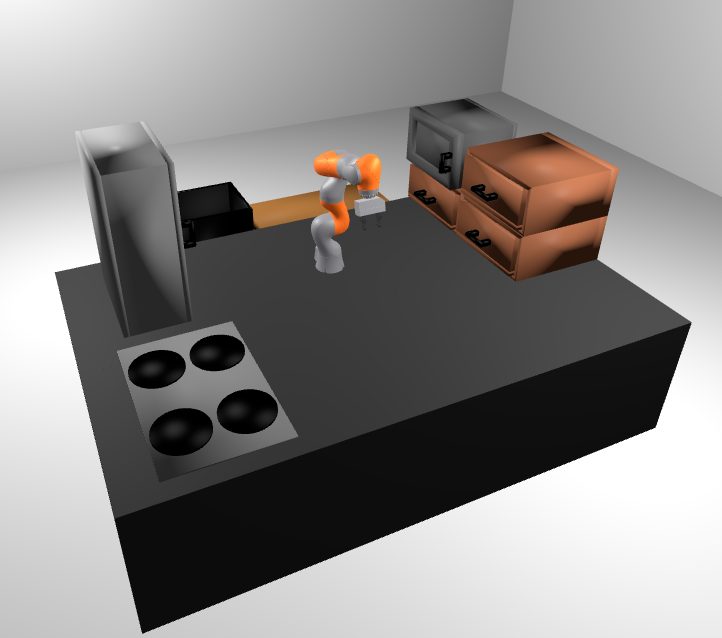
MIT 6.4212 · 2024LLM and VLM-based high-level task planning for a robot arm in a simulated kitchen: stacking, sorting, and table setup with affordance-based actions and antipodal grasping.
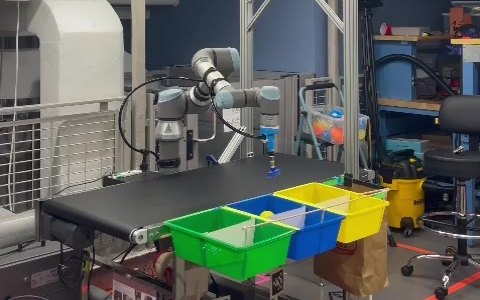
MIT 2.120 · 2025A pick-and-place cell where a RealSense depth camera detects bottles on a conveyor, PCA estimates their pose, and a UR5 with a custom ESP32-driven suction gripper sorts them into bins by type.
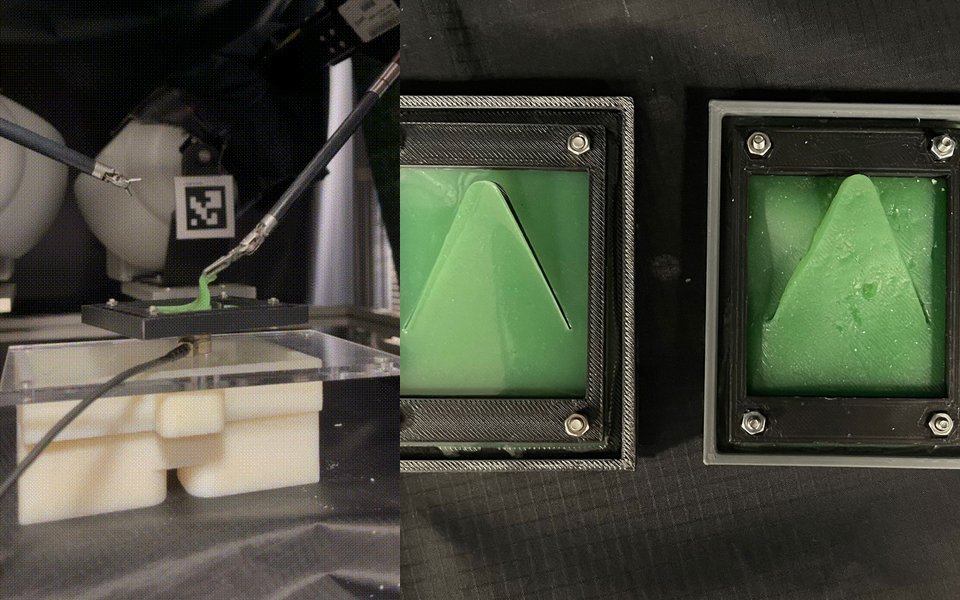
Stanford · 2024Molded silicone tissue phantoms of four stiffnesses (Dragon Skin 30/10, Ecoflex 00-30/00-20), designed and 3D-printed matching fixtures, and measured retraction forces by hand and with the da Vinci robot to test how a learned retraction policy generalizes.
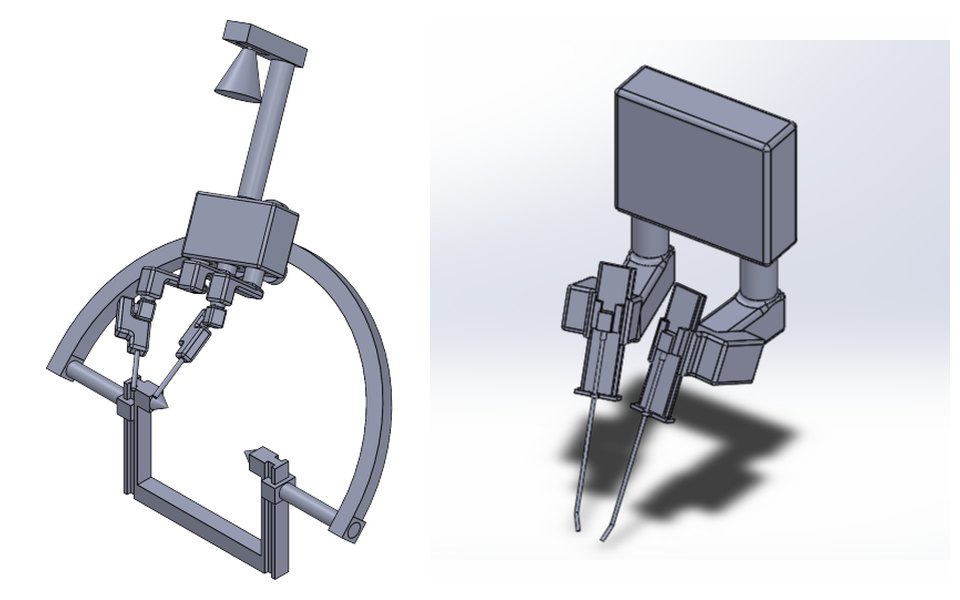
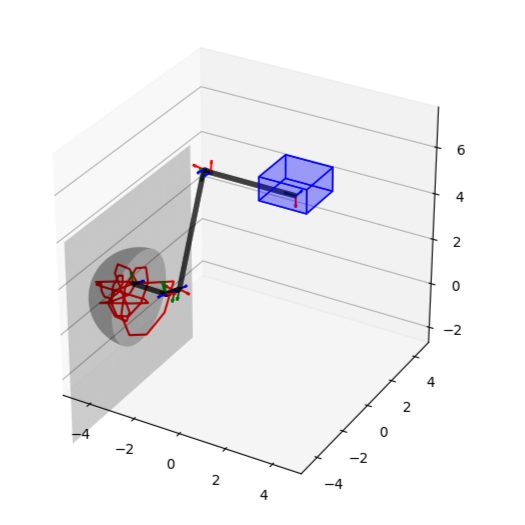
Stanford · 2023Designed a Mayfield-mounted rotating arch that carries two robotic arms for superficial neurosurgery, and optimized the arm link lengths so the end effectors can reach target trajectories. The optimized arms were modeled in CAD with interchangeable tools.
Stanford CS361 · 2024
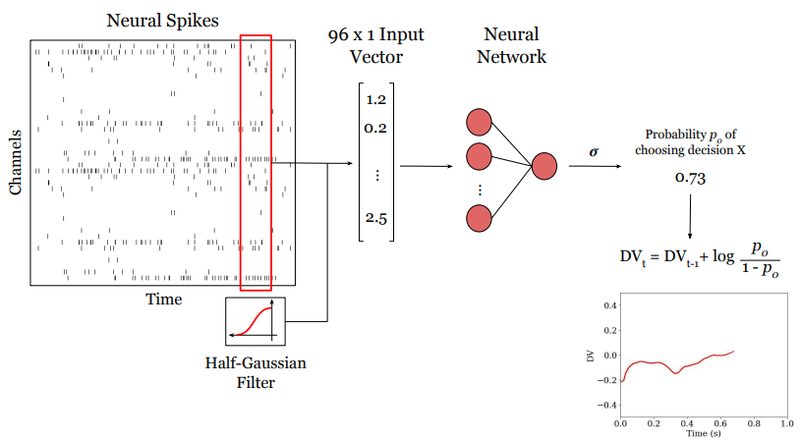
Stanford · 2023Decoded a monkey's choices in an iterated Battle of the Sexes game from neural spiking activity in real time, reaching up to 90% decoding accuracy.
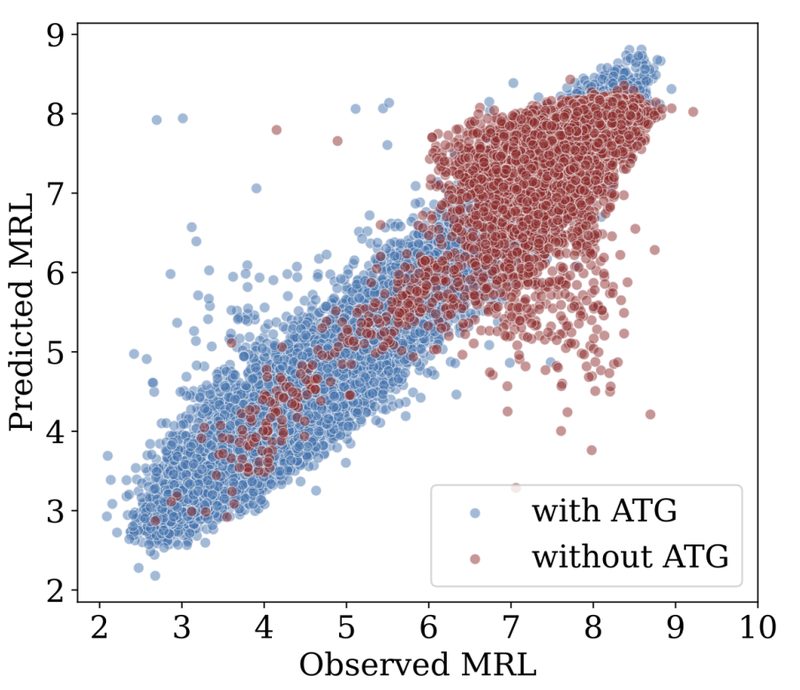
Stanford CS229 · 2023Transformer models that predict translation efficiency from mRNA 5′UTR sequences, motivated by mRNA therapeutics (best R² = 0.95).
Stanford · 2022–23
CNRS · 2022
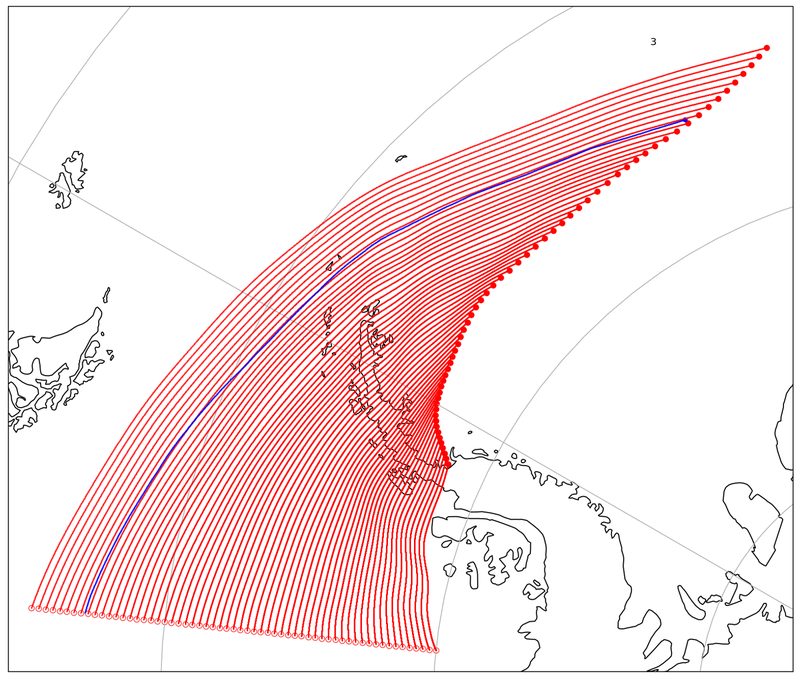
CNRS · 2021Compared real stratospheric balloon observations with virtual balloons in simulations to characterize a large-amplitude orographic gravity wave over the Antarctic Peninsula.
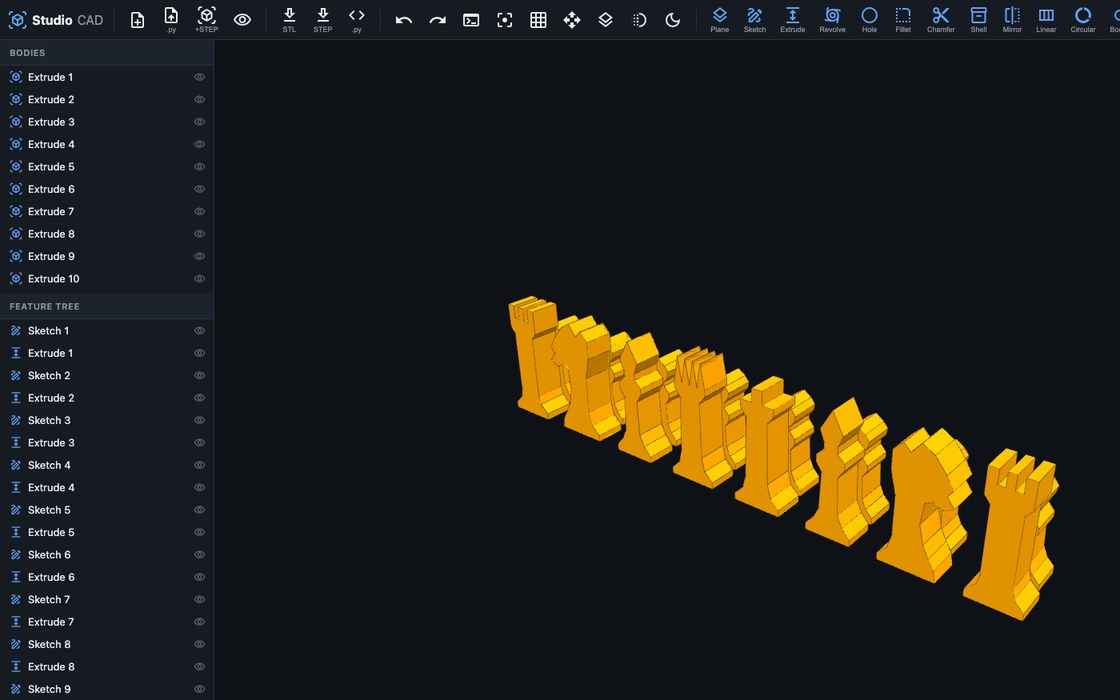
Open source · 2026An AI-native parametric CAD environment in the browser. It loads AI-generated CadQuery code (e.g. from CADFit) into an editable feature tree backed by a real B-rep kernel, then exports clean code back for an AI to keep editing. Built alongside CADFit (featured by MIT MechE).
Hardware, robots, and software I built for courses and for fun.
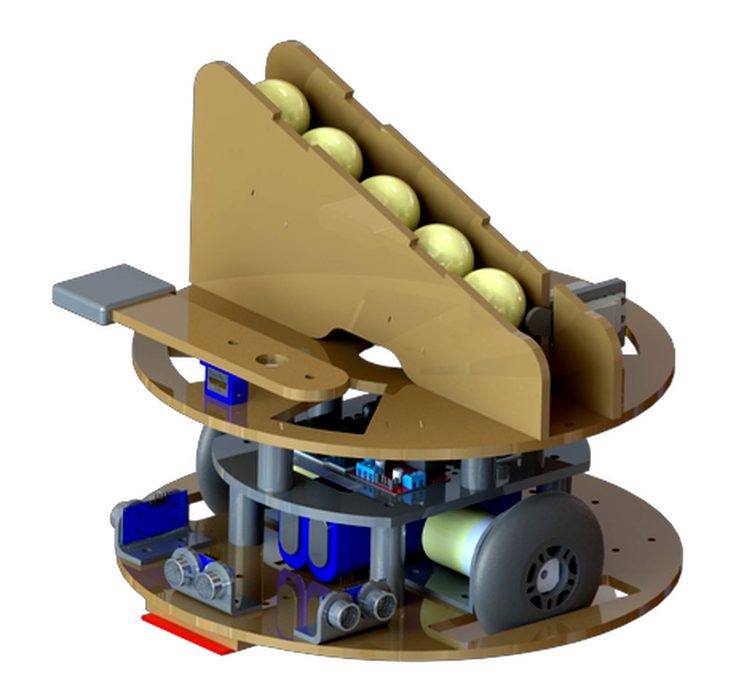
Stanford ME210An autonomous mechatronic robot designed, built, and programmed in Stanford's ME210 mechatronics course.
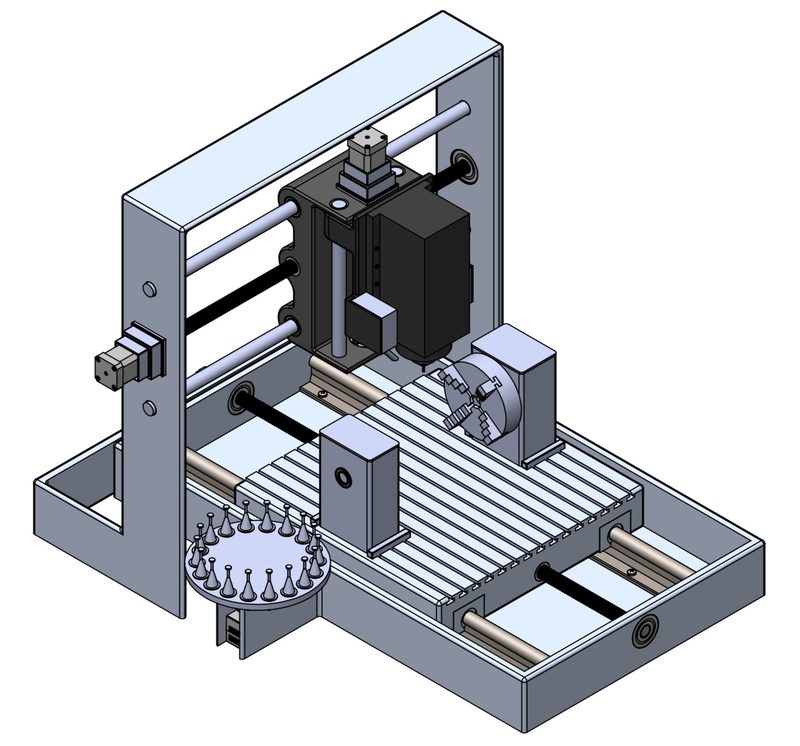
U of T · 2021Full mechanical design of a desktop 4-axis CNC mill, from concept selection to detailed CAD, technical drawings, and bill of materials.
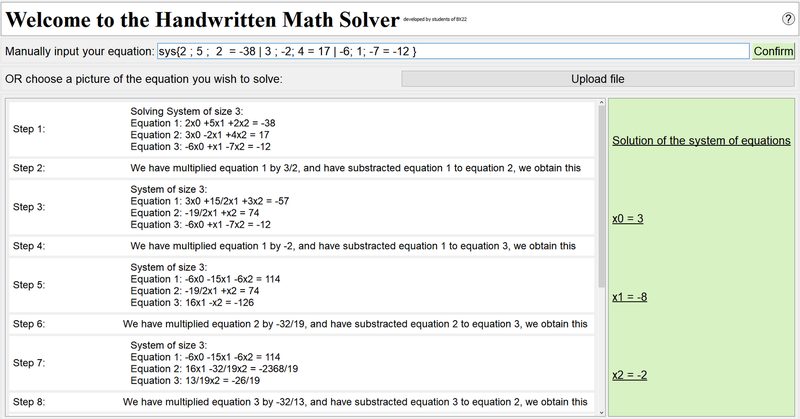
PolytechniqueA C++ application that solves handwritten and typed equations and systems step by step. I led the numerical-methods team.
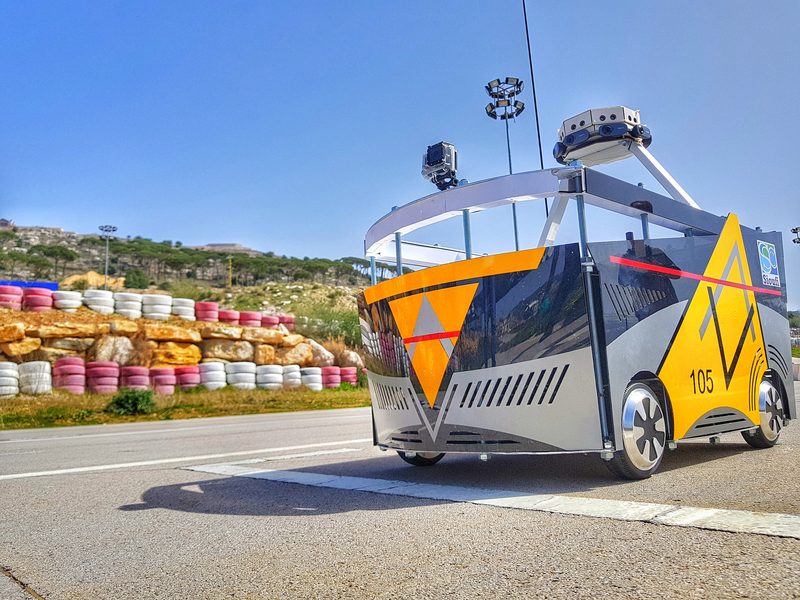
2018An autonomous delivery vehicle designed and built from scratch. It won first prize at the Science Fair organized by Université Saint-Joseph.
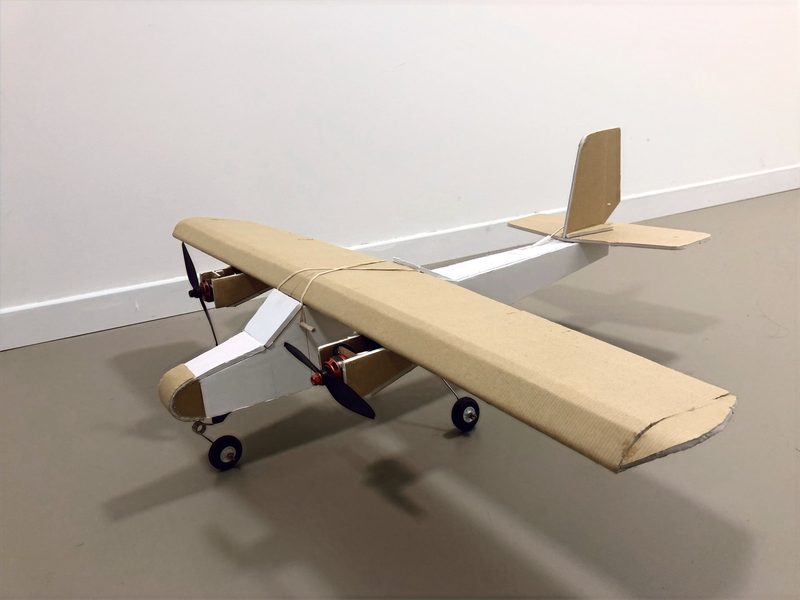
PersonalA radio-controlled airplane designed and built by hand.
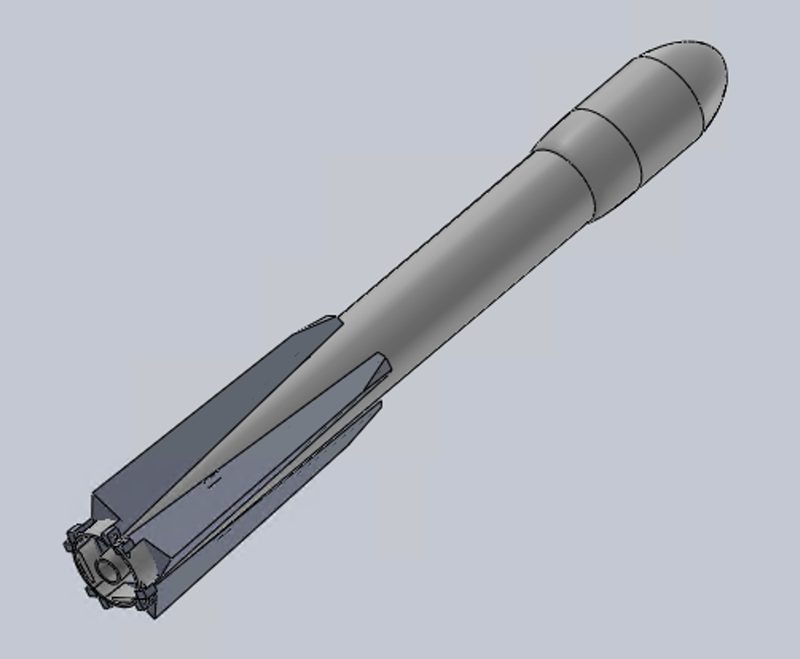
PersonalCAD design of a model rocket with thrust vector control.